Fast and Feasible: Agile Unicycle Motion Planning via Convex Inner Approximation
Sep 17, 2026·,,,·
0 min read
Jingxuan Tang
Haifeng Sun
Wang Xi
Jianping He
Abstract
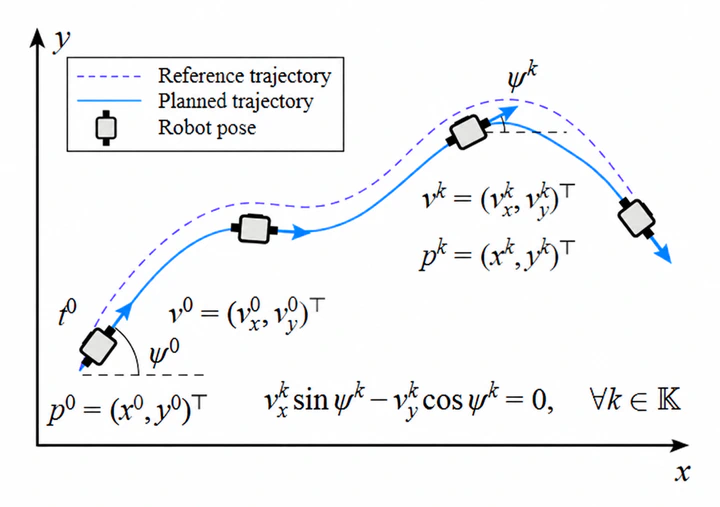
Agile navigation for unicycle-type robots demands a rigorous treatment of nonholonomic kinematics and actuator limits. However, reconciling the non-convex angular velocity constraints with the requirement for high-frequency control remains a computational and accuracy bottleneck. Existing Nonlinear Model Predictive Control (NMPC) solvers offer physical fidelity but often falter in real-time performance, while mainstream approaches like linearized approximations risk dynamical infeasibility during aggressive maneuvers. To bridge this gap, this paper proposes a fast and feasible motion planning framework. Our core insight is to reformulate the heading-change bound as bilinear inequalities exploiting its geometric structure, decomposing it into a convex-concave form that enables a strictly feasible convex approximation. By iteratively solving a sequence of standard Second-Order Cone Programs (SOCPs), our method guarantees anytime feasibility and monotonic convergence without sacrificing physical consistency. Numerical validations demonstrate that the proposed planner achieves NMPC-level solution quality with millisecond-level computation times, outperforming the baseline approaches in agile scenarios.
Type