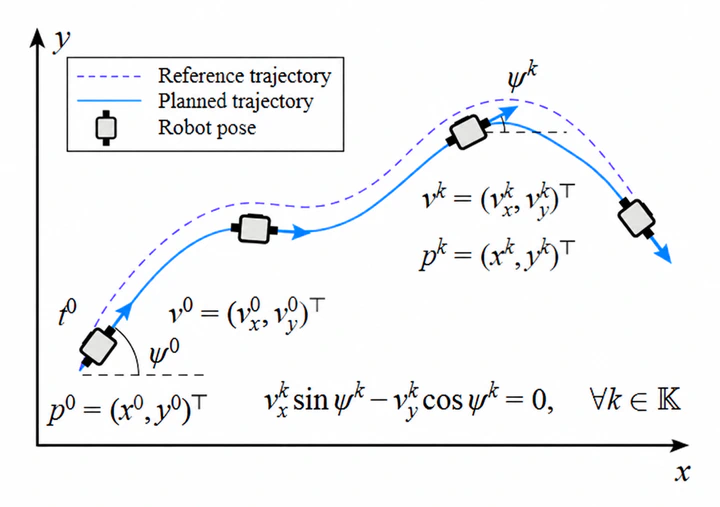
Fast and FeasibleSep 17, 2025 · 1 min readGo to Project SiteAgile Unicycle Motion Planning via Convex Inner ApproximationLast updated on Sep 17, 2026Motion Planning Convex Optimization Unicycle Robots AuthorsHaifeng SunUndergraduate Student ← GPT4D Dec 12, 2025Handcap Sep 1, 2025 →